[Software/Firmware Release Note] Six-axis Controller and the Matching Control Software-3.5.7.X-20240111
Six-axis Controller and the Matching Control Software-3.5.7.0-20240111
I. Update Scope
This update is applicable to CR series and Nova series, and the released versions are as follows:
- DobotStudioPro (PC): 2.8.0
- Dobot CRStudio (Android): 4.13.0
- Controller: 3.5.7.0
- CR slave firmware:
- Servo: 4.1.6.0
- Tool IO: 3.3.7.0
- Nova slave firmware:
- Universal IO: 2.2.0
- Tool IO: 6.1.1.0
- User Guide:
- DobotStudio Pro V2.8.0 User Guide (CR&Nova)
- Dobot CRStudio User Guide (CR&Nova) V4.13.0
- TCP_IP Remote Control Interface Guide (V3)
II. Compatibility
To reduce robot vibration, the CR series now defaults to enabling the start-stop vibration suppression function. This might cause users to observe changes in the cycle time when running the same script before and after the upgrade. Users can restore the original cycle time by disabling the vibration suppression function or readjusting the robot’s motion parameters.
III. Key Updates
- New TCP Commands: Enhanced secondary development experience.
- Display of Robot SN Code: Facilitates quick viewing of SN codes.
- Support for Switching of Nova Tool DO Types: Allows adaptation to more types of end tools (hardware support required).
IV. Update Content
- Added the following TCP commands.
- Pause and Continue commands: Can be used together to pause or continue TCP single-motion commands.
- SetUser, SetTool, CalcUser, CalcTool commands: Function similarly to script definitions, allowing changes to user and tool coordinate systems.
- PalletCreate and GetPalletPose commands: Simplify the setup of high-precision pallet picking and placing applications.
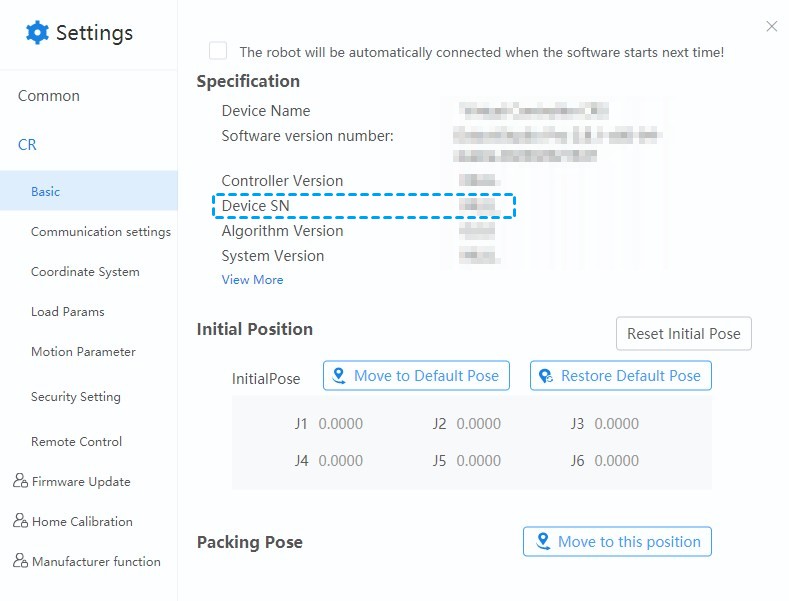
- Added SN-code display in Settings page.
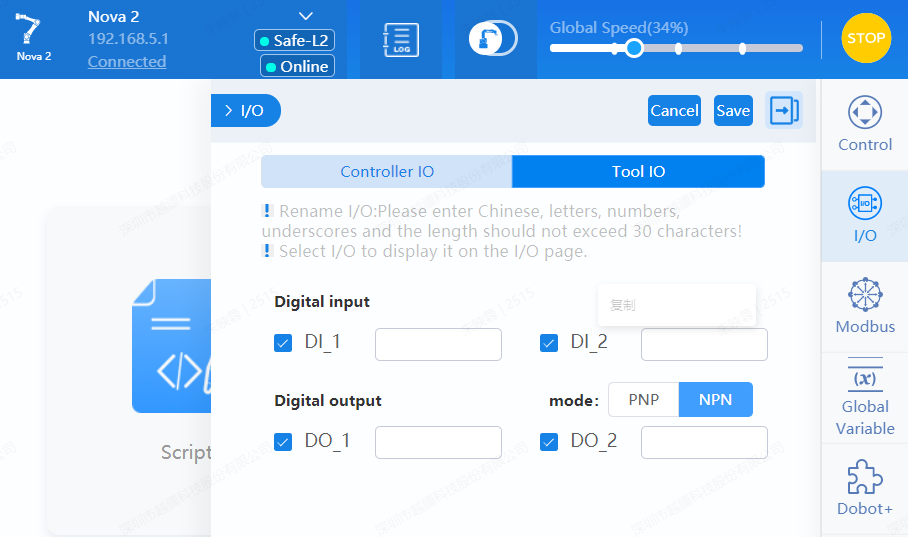
- Added type-setting function for Nova tool DO, which can switch between NPN (default) and PNP types. If robot hardware does not support switching, an error prompt will be displayed.
- Added enable, disable, and global speed settings interfaces for Modbus remote control.
- Enable: Coil register, PLC address 00101
- Disable: Coil register, PLC address 00102
- Global speed settings: Holding register, PLC address 40101 (U16)
- New alarms for joint MCU overheating and large deviation in joint position encoder.
- Users now can control the gripper or other tools via the end button in alarm status.

V. Bug Fixes
Fixed the following issues:
- No prompt is given after the robot fails to enter the drag mode.
- Sync parameter error in collision backoff mode when the script is running.
- Inconsistent DO (extended DO) actual status and interface display.
- Incorrect feedback value for TCP RobotMode in collision status.
- Sudden acceleration at specific positions with TCP ServoJ command.
- Incorrect speed planning with RunTo command.
- Error occurs when using TCP StopDrag command to exit drag mode.
- Inability to use DH-Robotics gripper IO normally.
- Error occurs after triggering the reduced mode.
- Incorrect function of TCP StopScript command.

 Metal Processing
 Automotive
 Food & Beverage
 Chemical
 Consumer Electronics
 Healthcare
 New Retail
 Semiconductor
 Welding
 Palletizing
 Loading and Unloading
 Assembly
 Bin Picking
 Gluing
 Insertion
 Polishing