
 Metal Processing
 Automotive
 Food & Beverage
 Chemical
 Consumer Electronics
 Healthcare
 New Retail
 Semiconductor
 Welding
 Palletizing
 Loading and Unloading
 Assembly
 Bin Picking
 Gluing
 Insertion
 Polishing

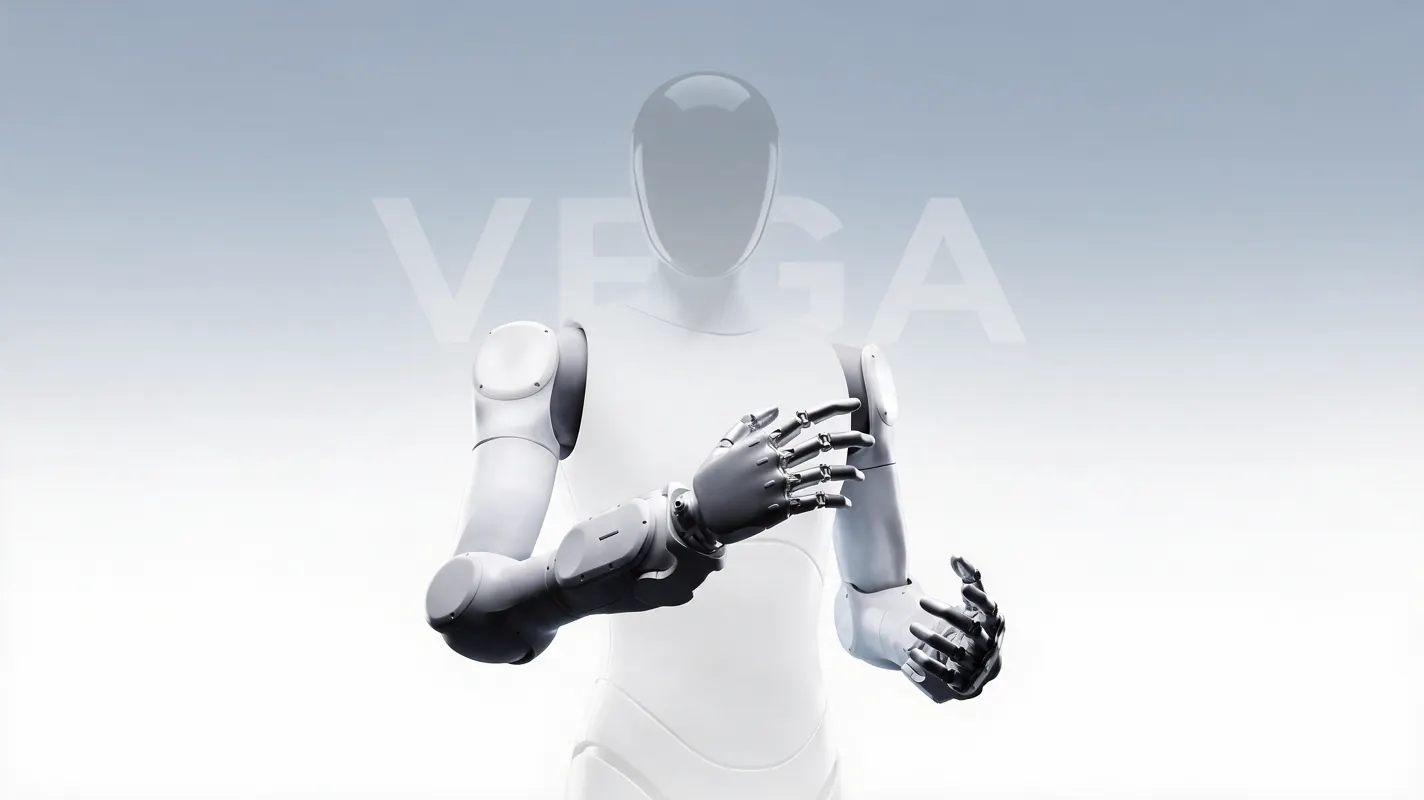
Payload-to-Weight Ratio
58%
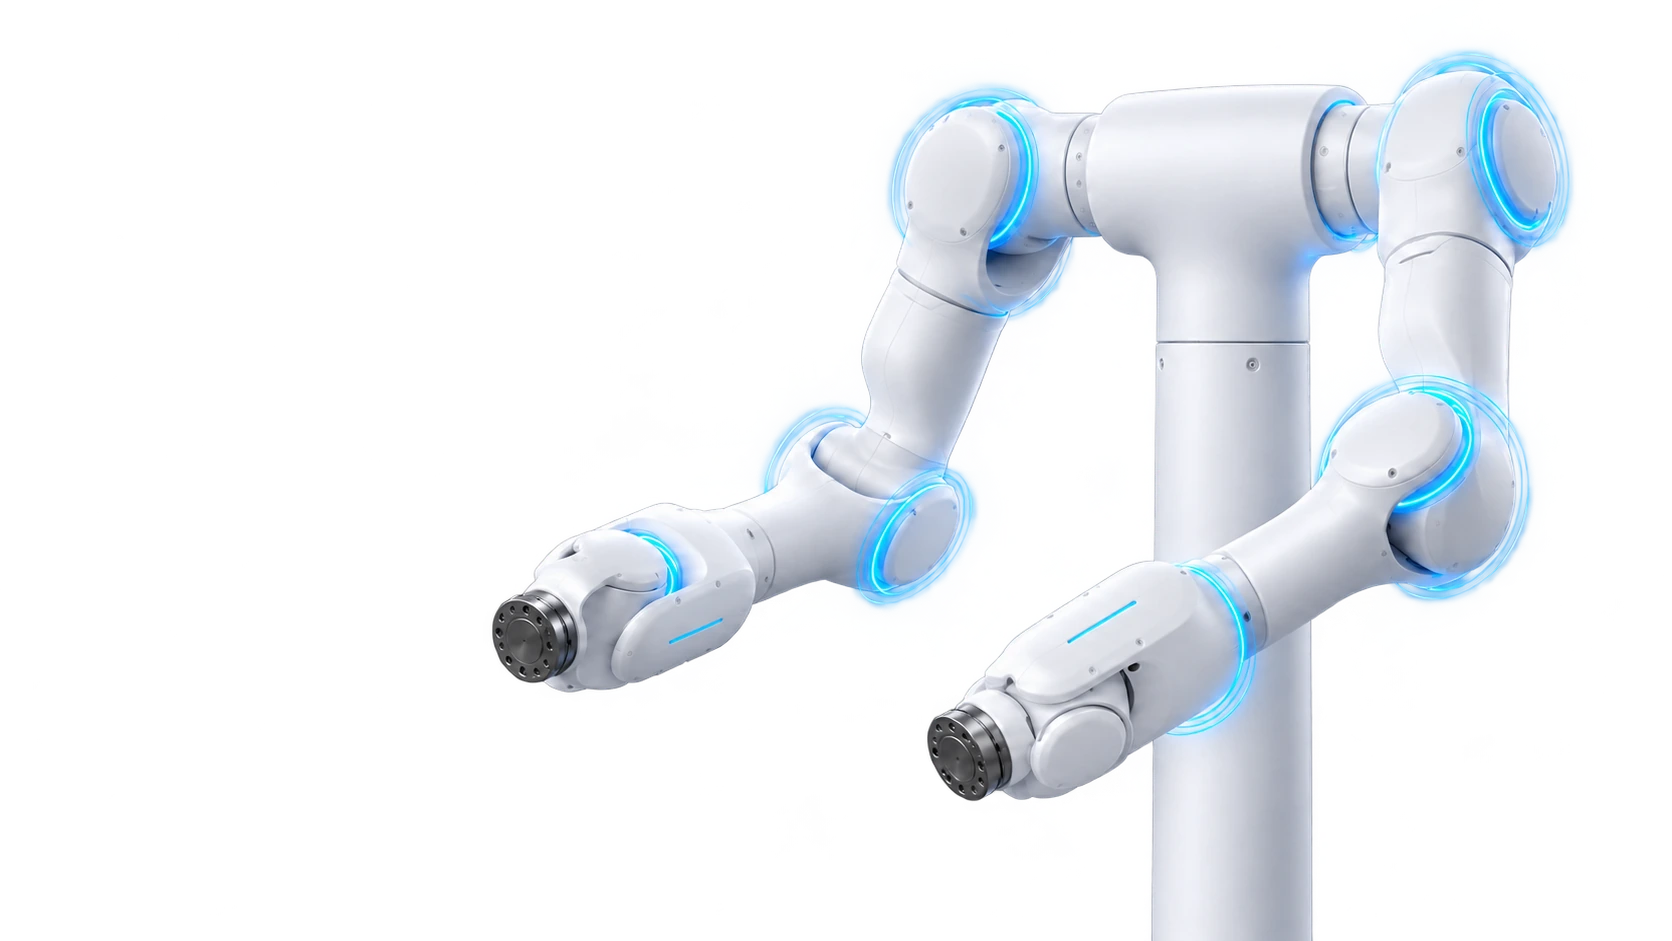
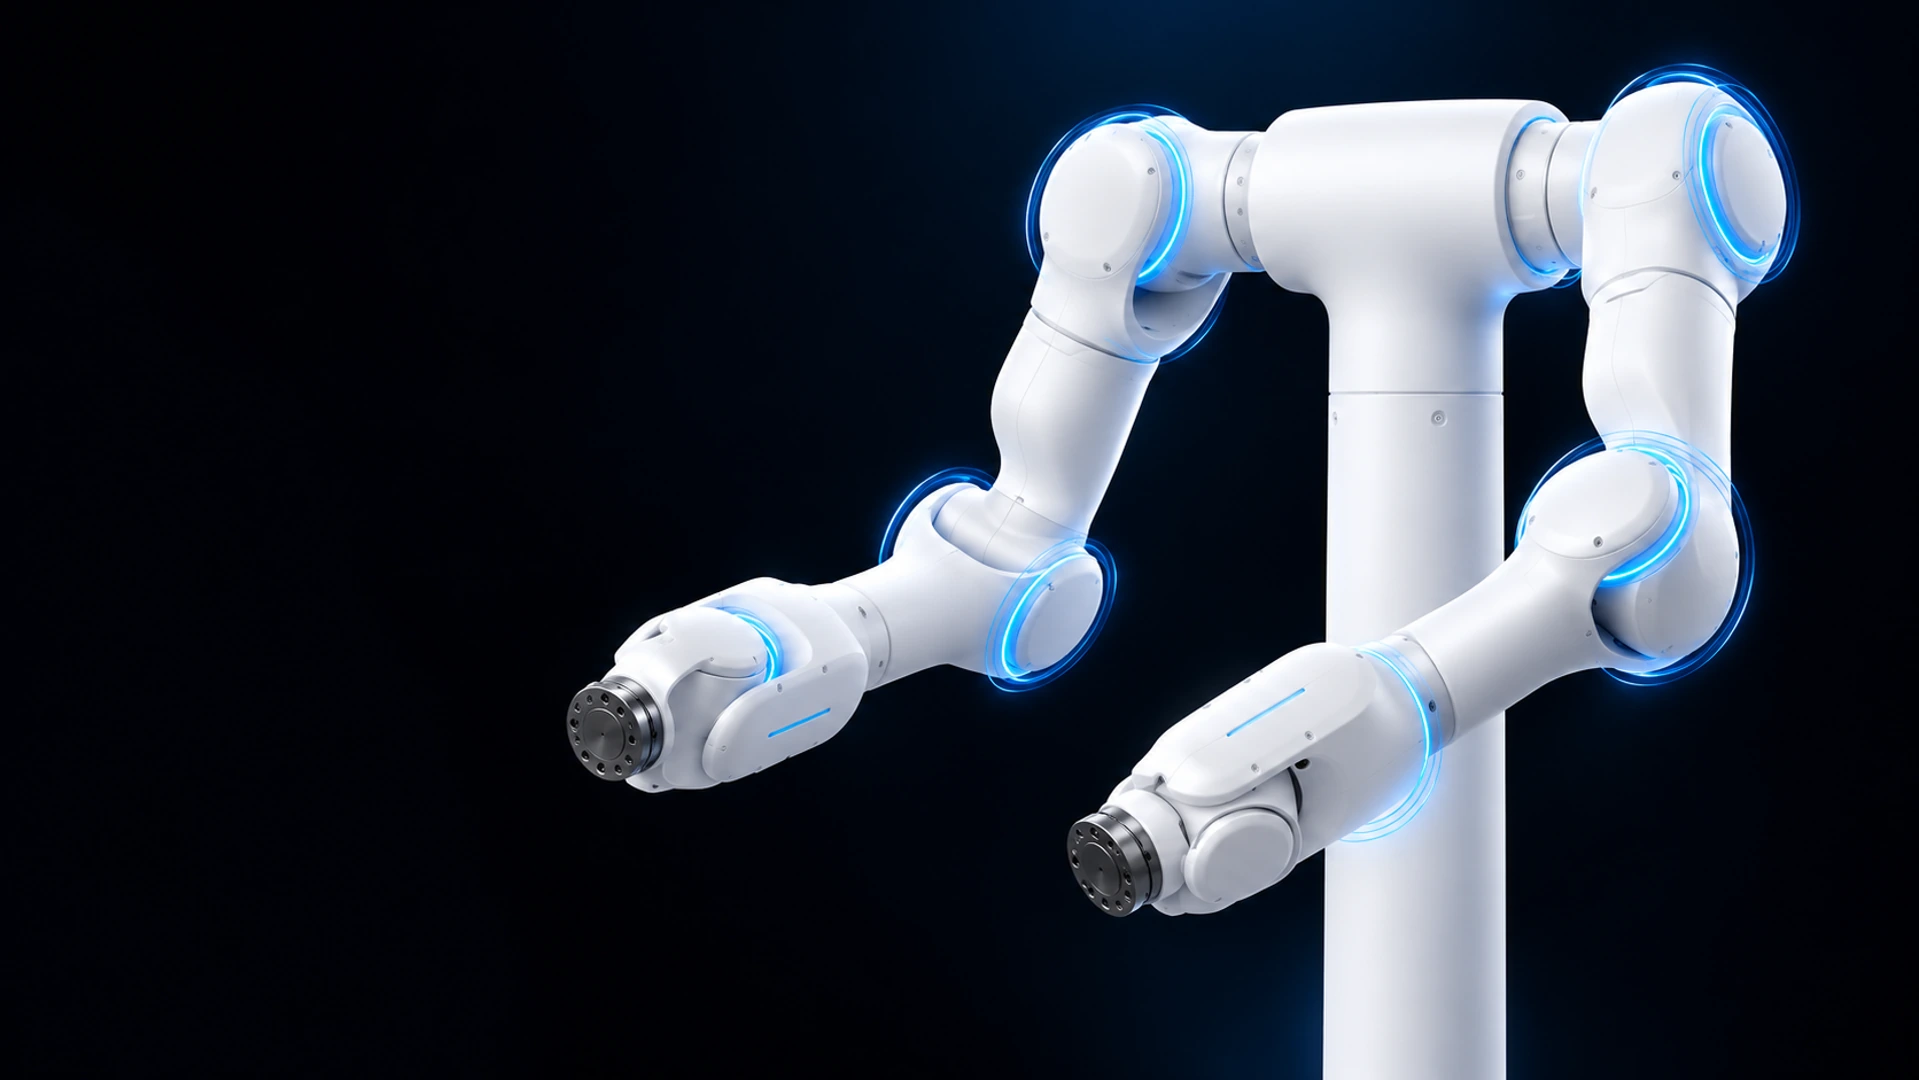
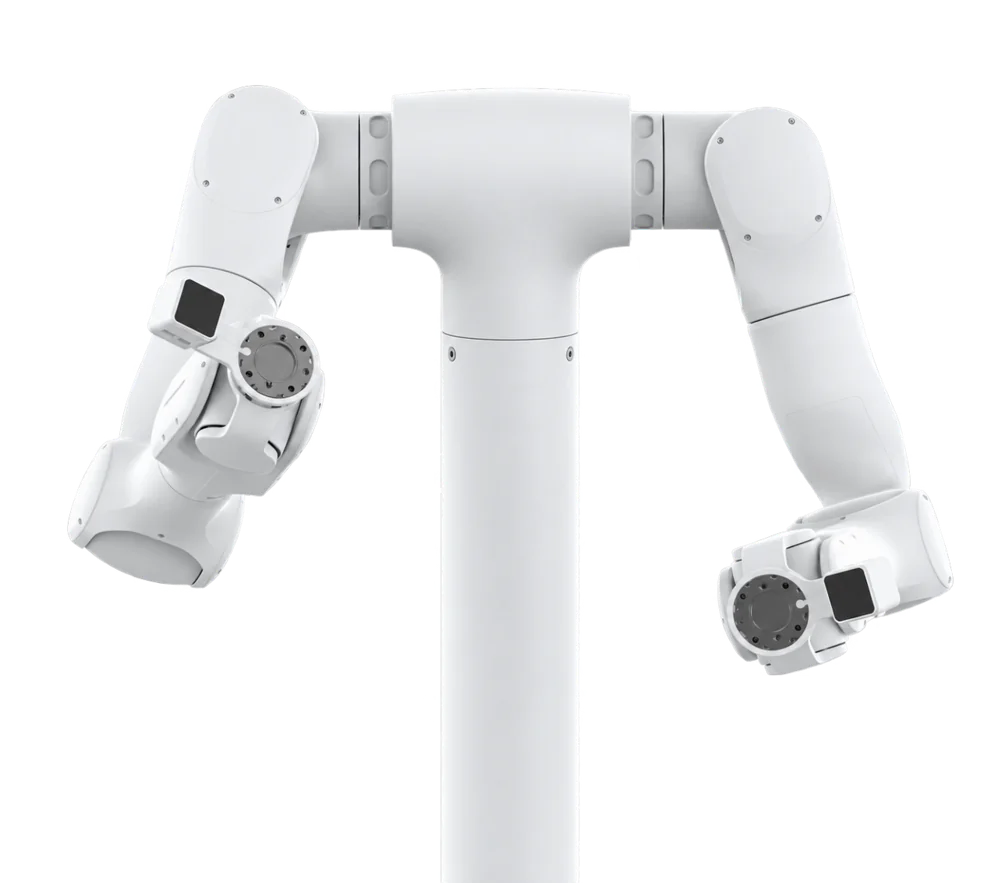
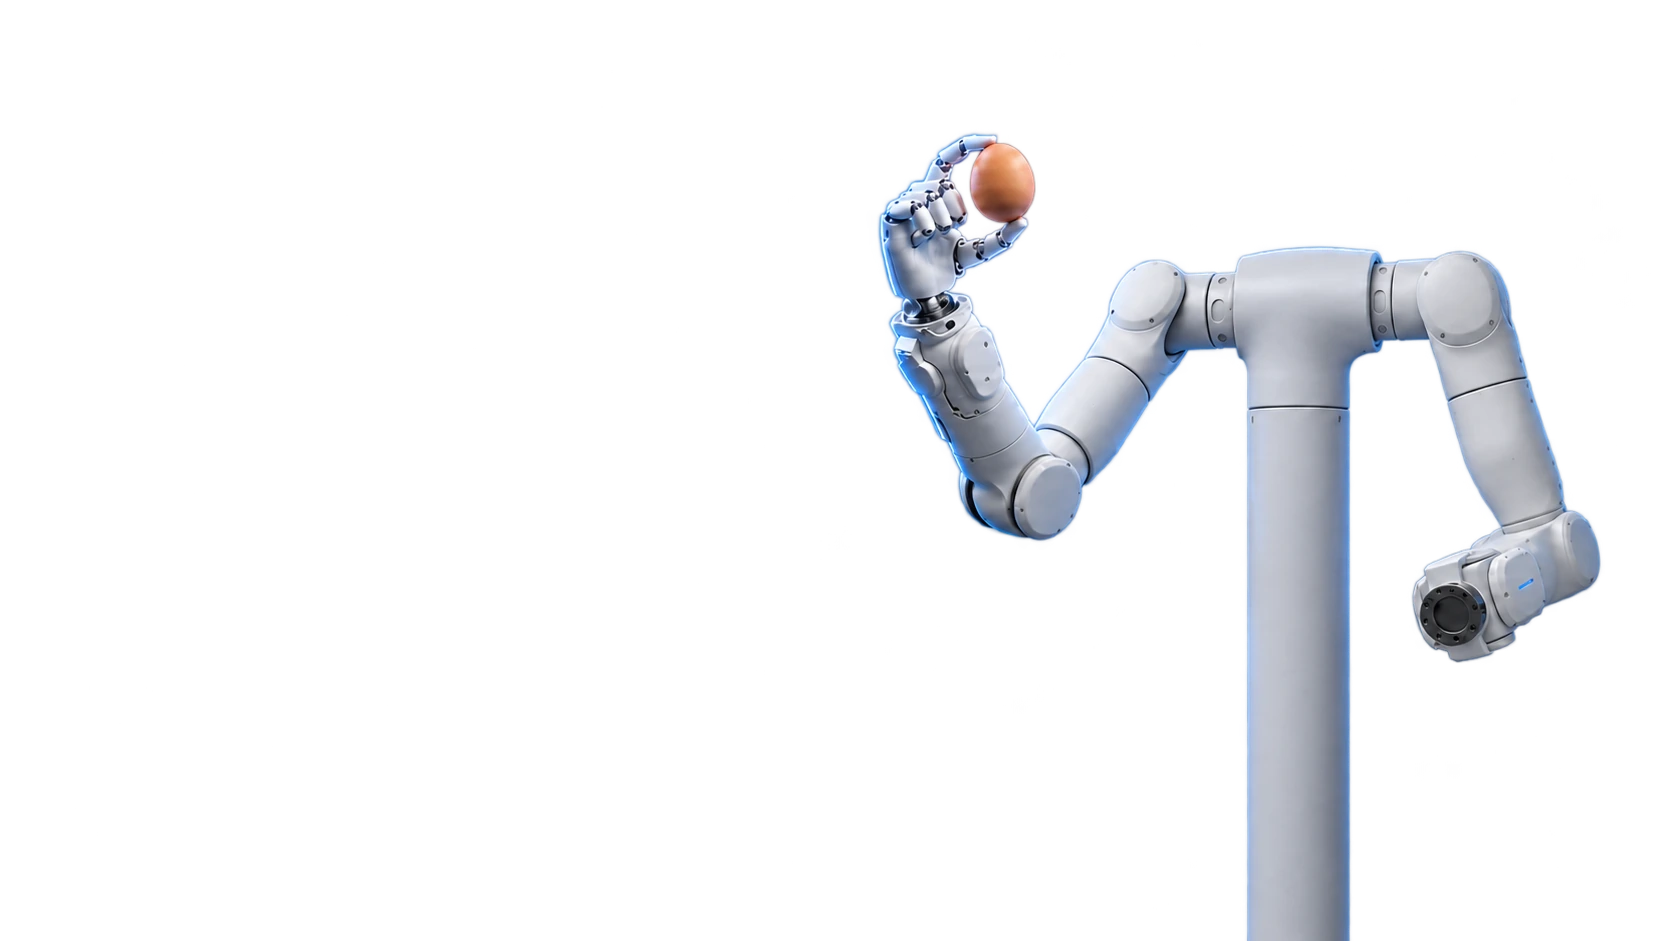
Next-generation 7-axis Force-controlled Arm, Purpose-built for Embodied AI
50,000 Hours
Mean Time Between Failures (MTBF)
66%
Higher MTBF than the Industry Average
IP54
Dust and Splash Protection Built for Industrial Environments
ISO 13849 Standard Torque Sensors and Electromagnetic Brakes on Every Joint
±0.03 mm
Industrial-grade Position Repeatability
A lightweight design for easy integration, with ample payload capacity for grippers, cameras, and workpieces.
Payload-to-Weight Ratio
58%
Arm Weight
12 kg
Rated Payload
7 kg
5 A Peak Current 66% Above the Industry Average
Compatible with a wider range of end effectors to unlock the creative potential of Physical AI.
Redundant 7-axis Design 725 mm Reach
One More Axis. Greater Dexterity.
Large Hollow-bore Design with Internal Cable Routing Easy Integration. Clean, Unobstructed Motion.
Performance You Can See Engineering You Can Appreciate
Torque Sensors as Standard on Every Joint Collision Detection and Hand-guided Teaching
Power with Precise Control
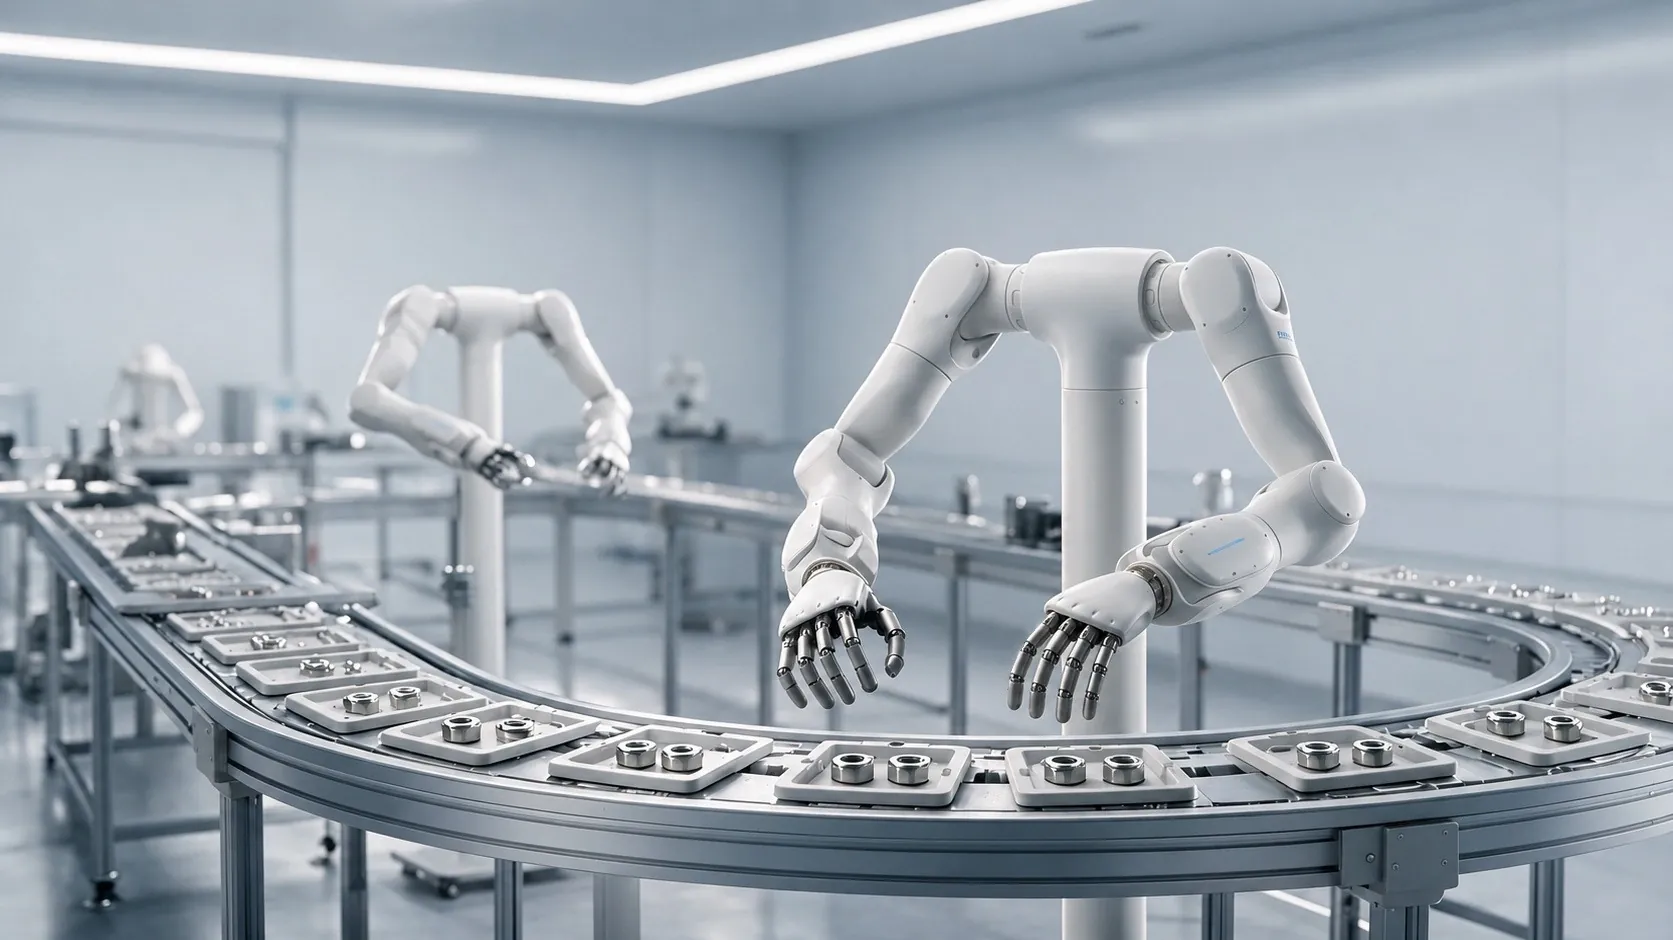
Bin Handling · Workstation Loading and Unloading · Equipment Operation · Door and Button Operation
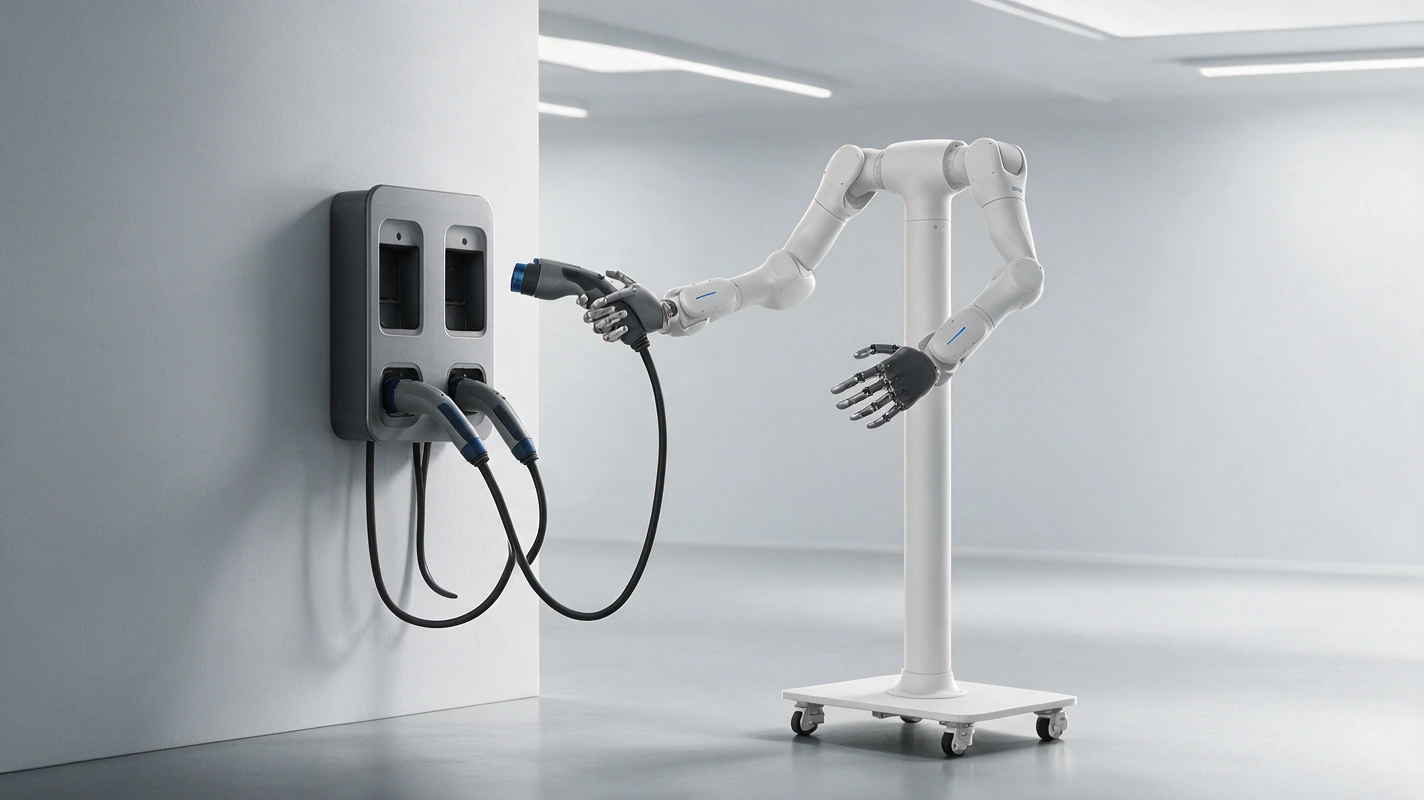
EV Charging Connector Insertion and Removal · Connector Assembly · Wiring Harness Connection · Shaft-in-hole Assembly
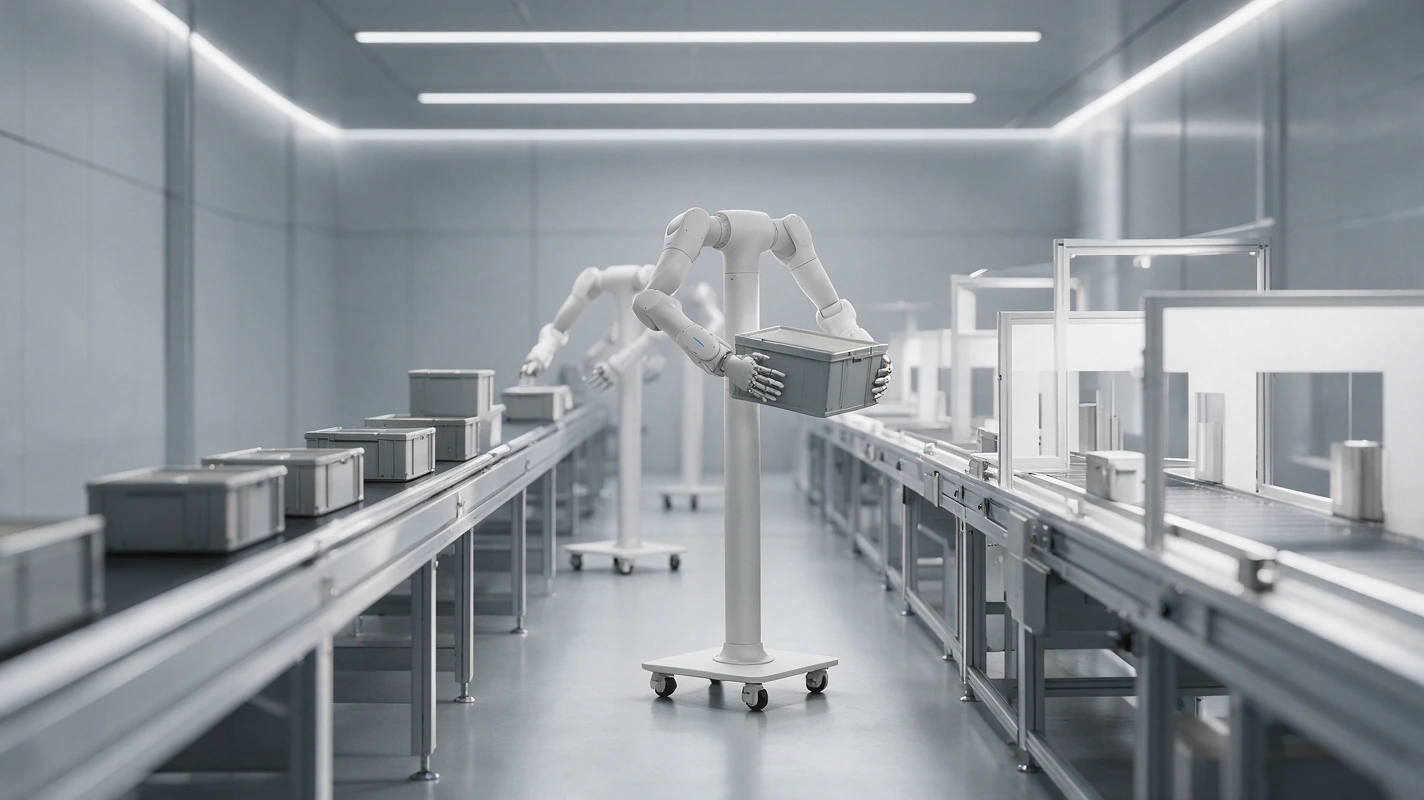
Panel Handling · Long-part Assembly · Flexible Cable Management
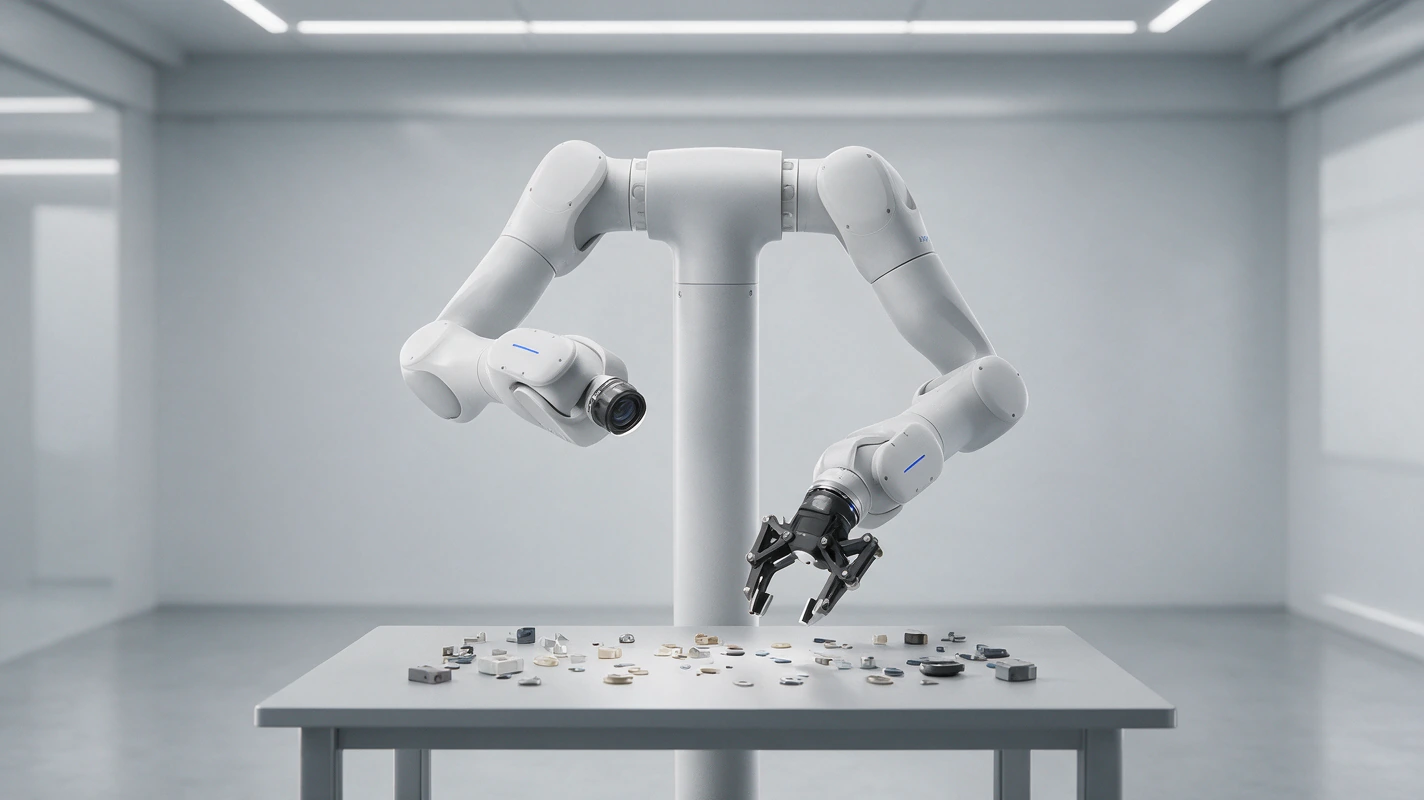
Teleoperation · Imitation Learning · VLA Training · Torque Data Collection
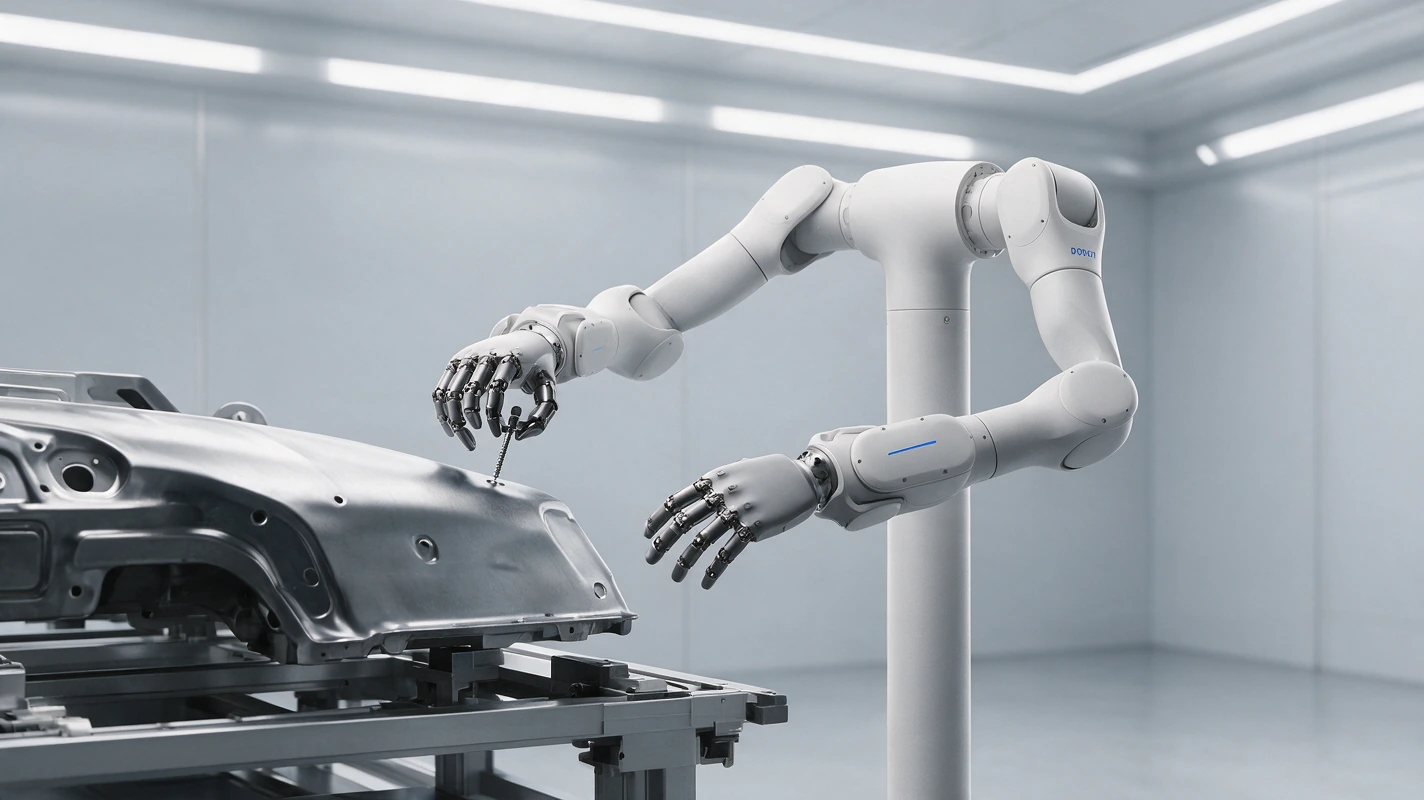
Loading and Unloading · Inspection · Adhesive Dispensing · Screwdriving · Small-part Assembly
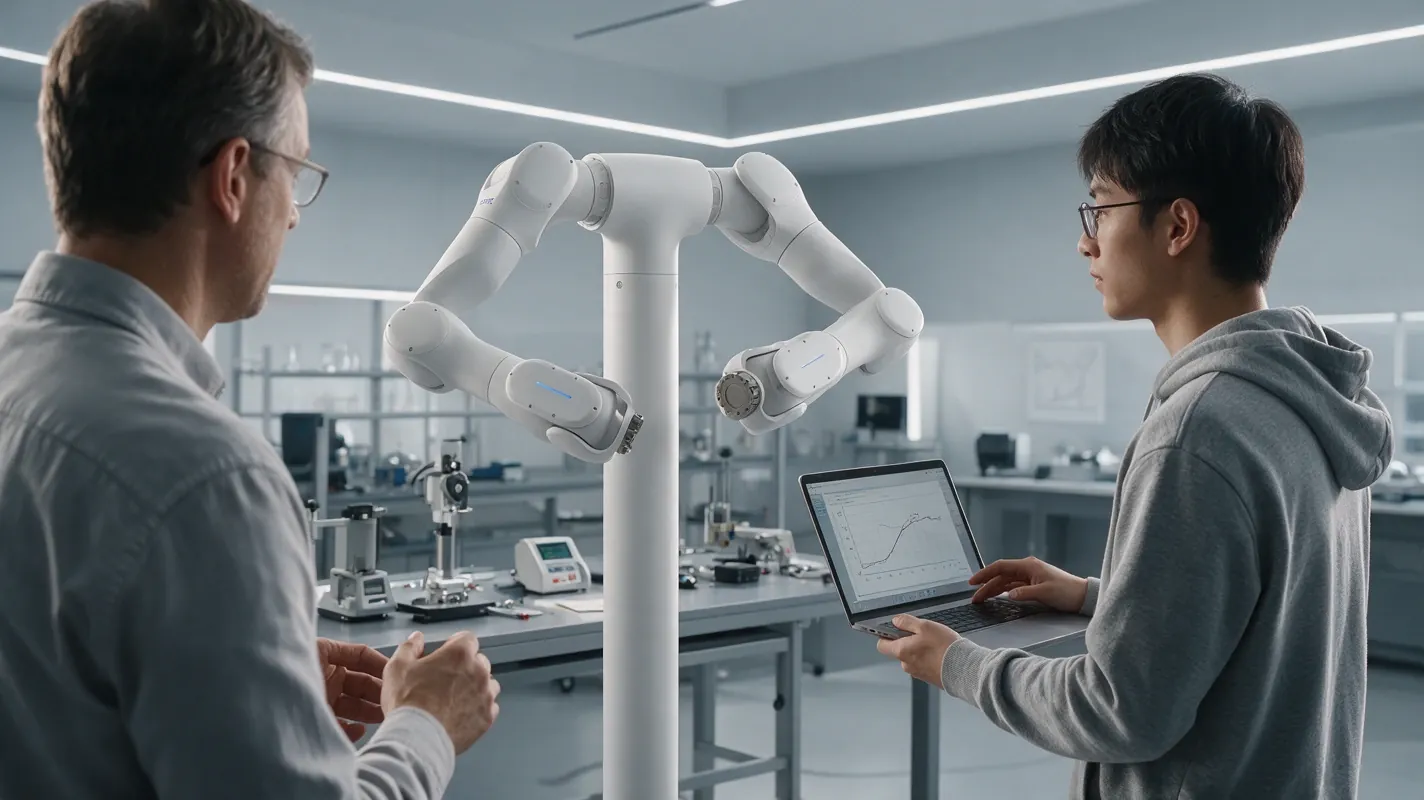
Force Control Research · Motion Planning · Dual-arm Coordination · Algorithm Validation
| Rated Payload | 7 kg |
|---|---|
| Reach | 725mm |
| Position Repeatability | ±0.03 mm |
| IP Rating | IP54 |
| Joint Brakes | Brakes on All Joints |
|---|---|
| Joint Torque Sensors | Standard |
| Force/Torque Control Accuracy | ≤ 0.15 N; ≤ 0.05 N·m |
| Force/Torque Control Resolution | ≤ 0.01 N·m |
| Closed-loop Force Control Bandwidth | ≥ 100 Hz |
| Degrees of Freedom | 7 |
|---|---|
| Arm Weight | 12 kg |
| Communication Protocol | EtherCAT |
| Tool Communication Interfaces | Two interfaces supporting EtherCAT, CAN, and RS-485 |
| Tool Power Interface | 24 V power supply (rated current: 3 A; maximum current: 5 A) |
| Input Voltage | 30–67 V DC; typical: 48 V DC (±15%) |
| Camera Cabling | GMSL cable internally routed to the tool end |
| Joint Range of Motion | J1: ±178° J2: -90° / +120° J3: ±178° J4: -60° / +145° J5: ±178° J6: ±60° J7: ±90° |
| Joint Speed | J1, J2: 180°/s J3–J7: 225°/s |
Next-generation 7-axis Force-controlled Arm, Purpose-built for Embodied AI
Mean Time Between Failures (MTBF)
Higher MTBF than the Industry Average
Dust and Splash Protection
Built for Industrial Environments
ISO 13849 Standard
Torque Sensors and Electromagnetic Brakes on Every Joint
Industrial-grade Position Repeatability
A lightweight design for easy integration, with ample payload capacity for grippers, cameras, and workpieces.
Payload-to-Weight Ratio
58%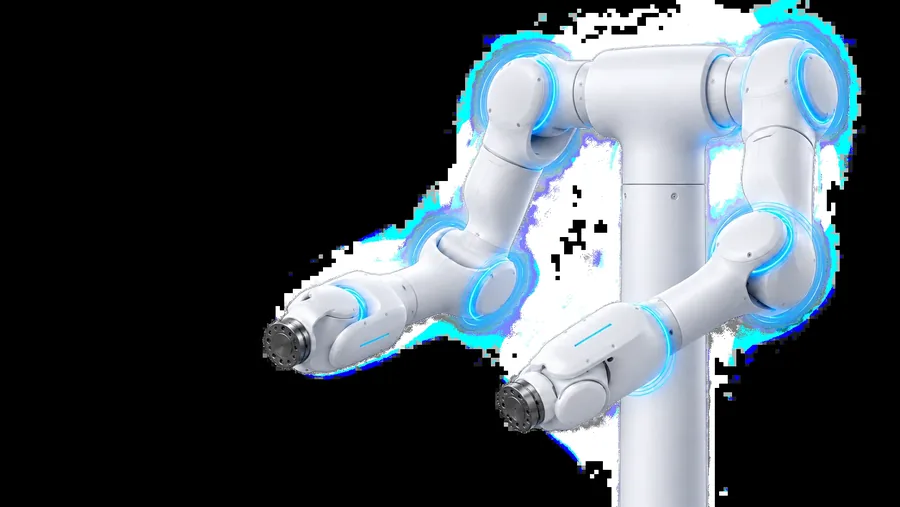
Arm Weight
12 kg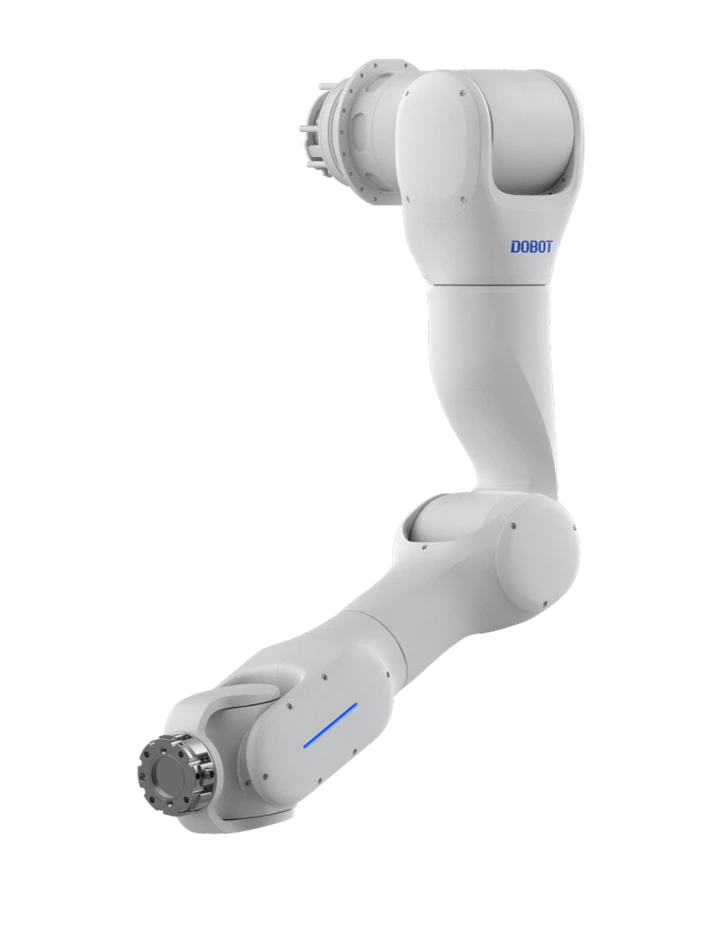
Rated Payload
7 kg5 A Peak Current
66% Above the Industry Average
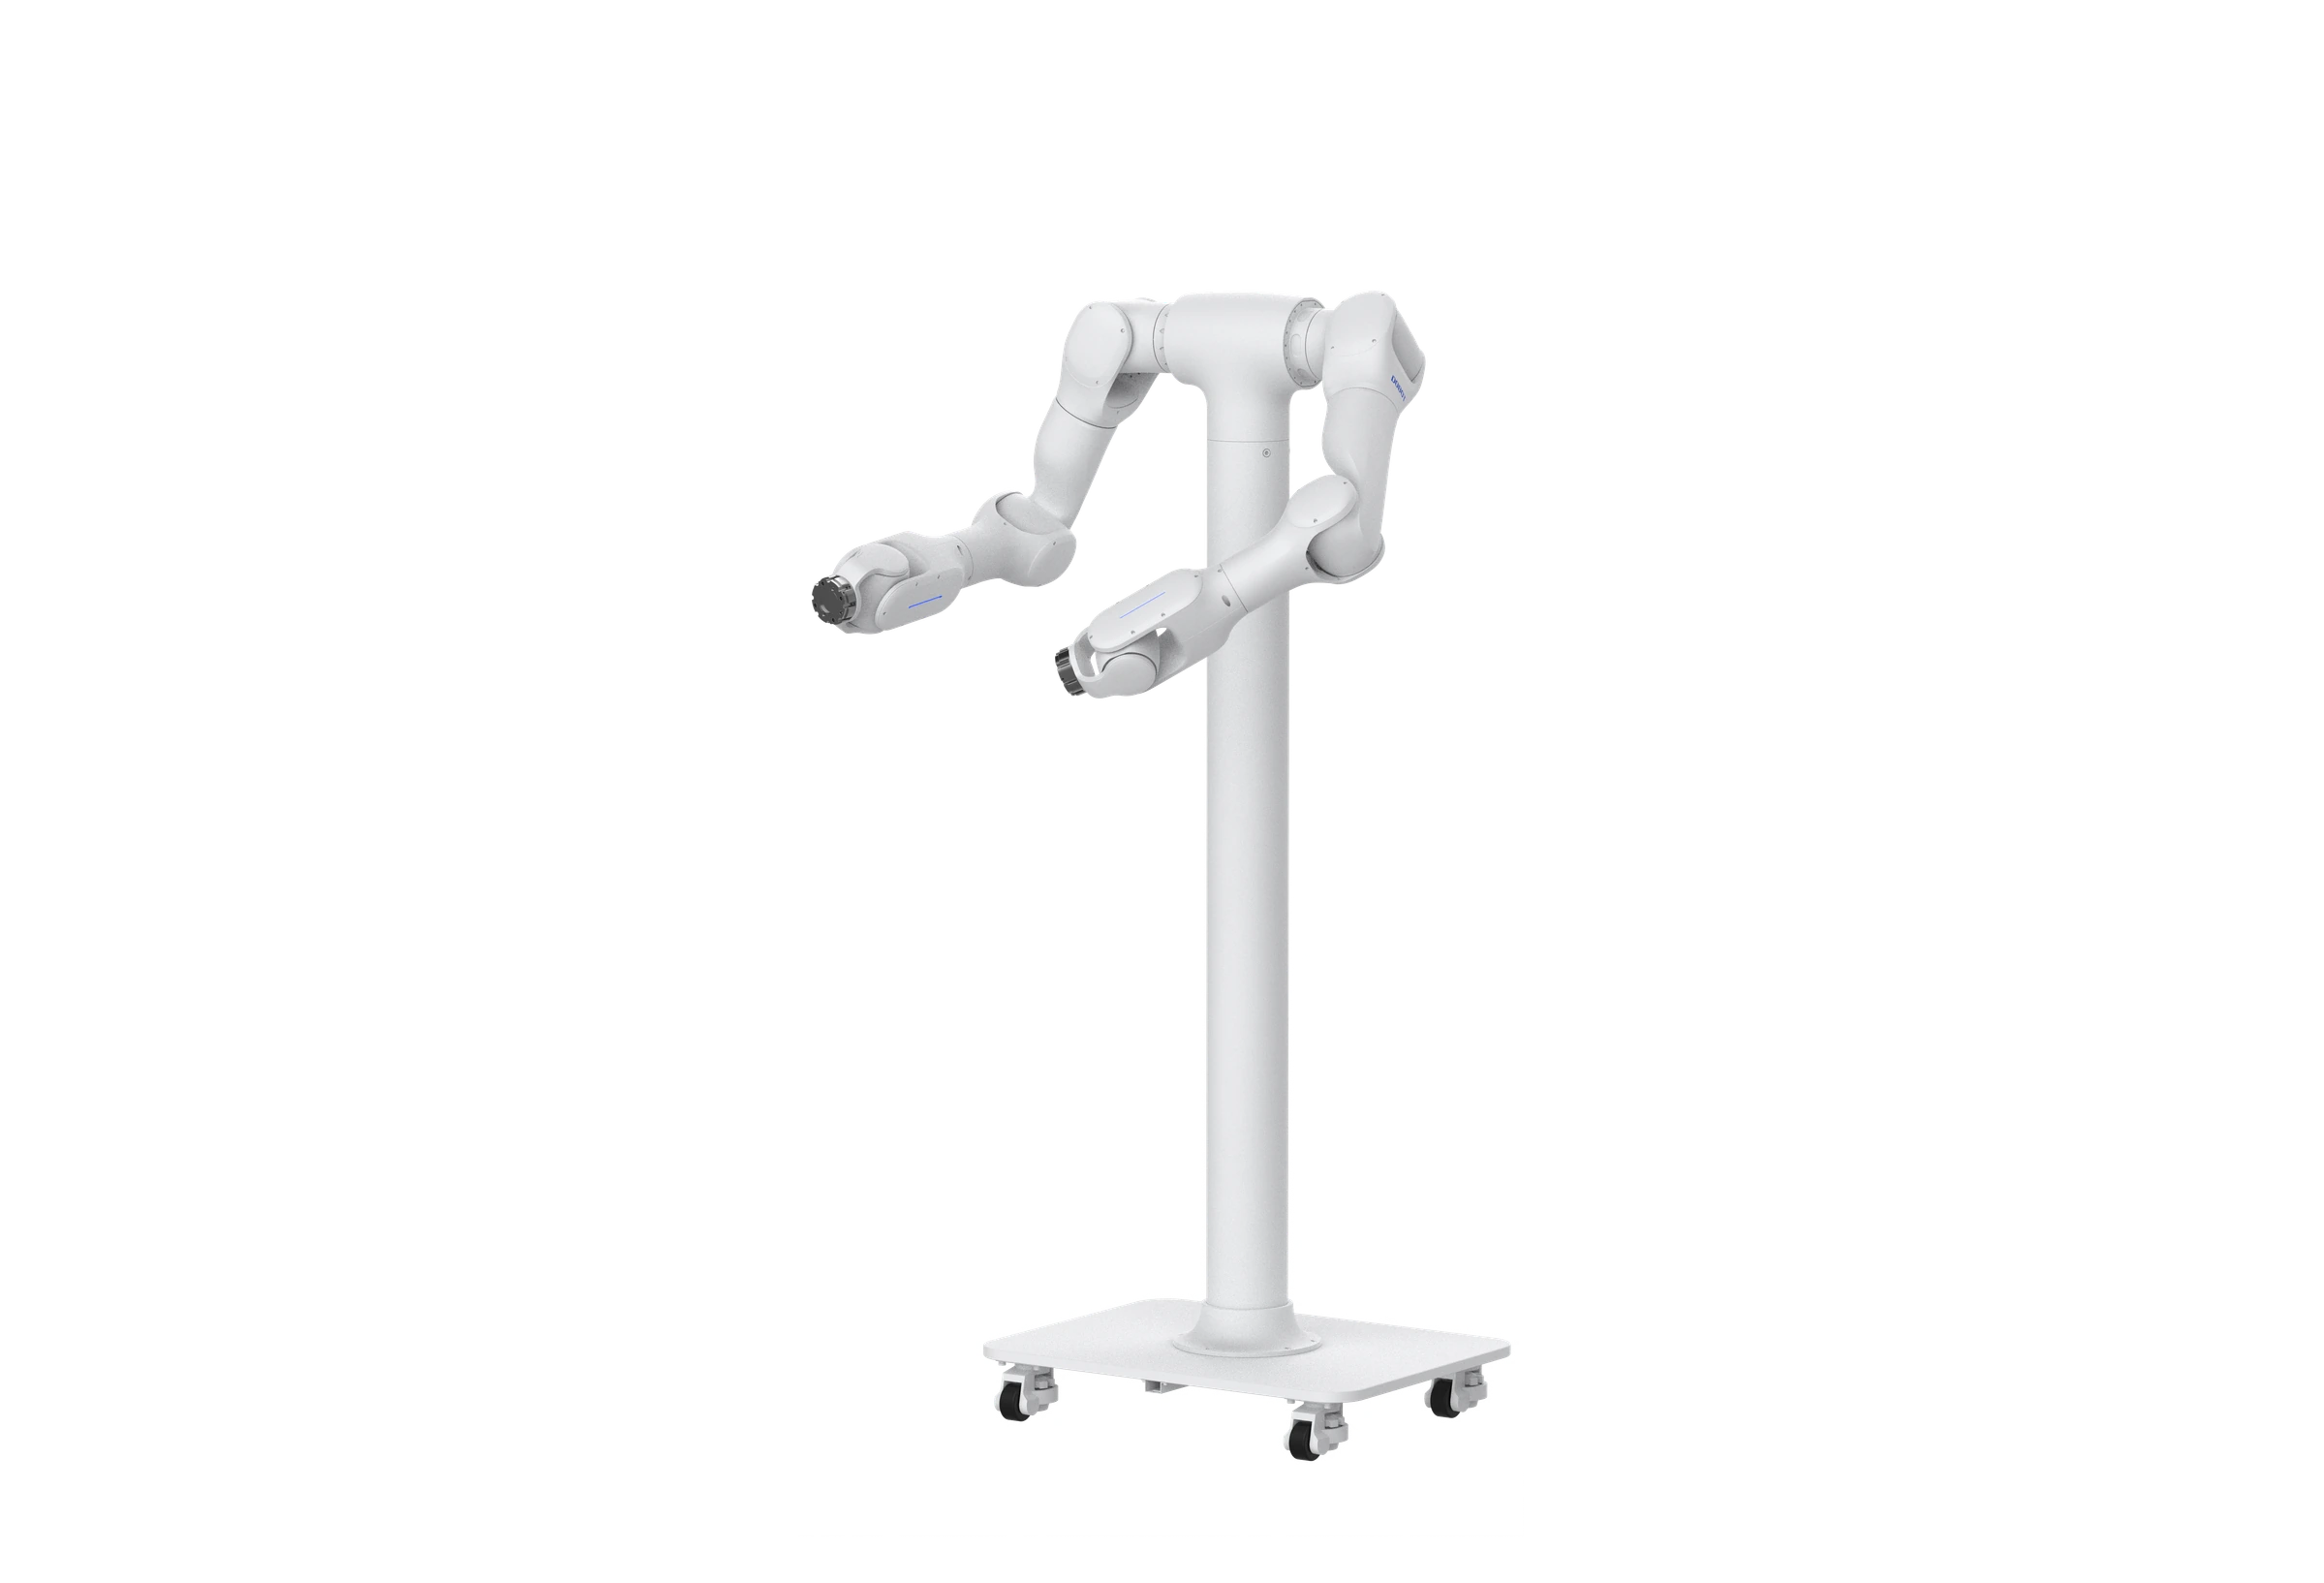
Compatible with a wider range of end effectors to unlock the creative potential of Physical AI.
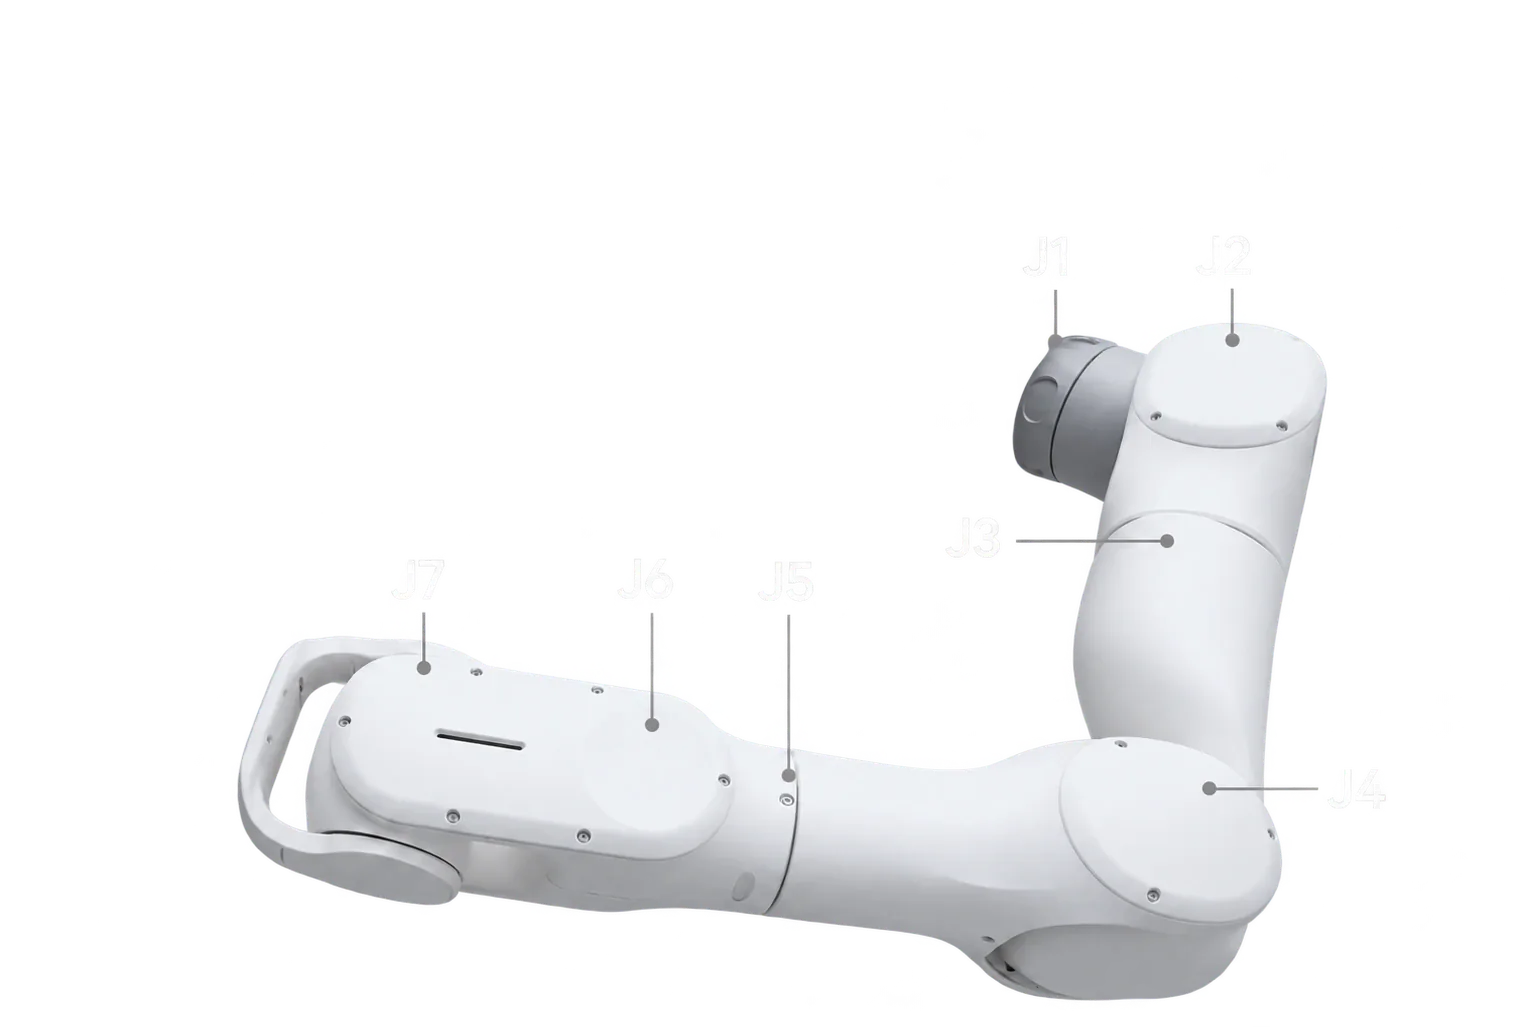
Redundant 7-axis Design
725 mm Reach
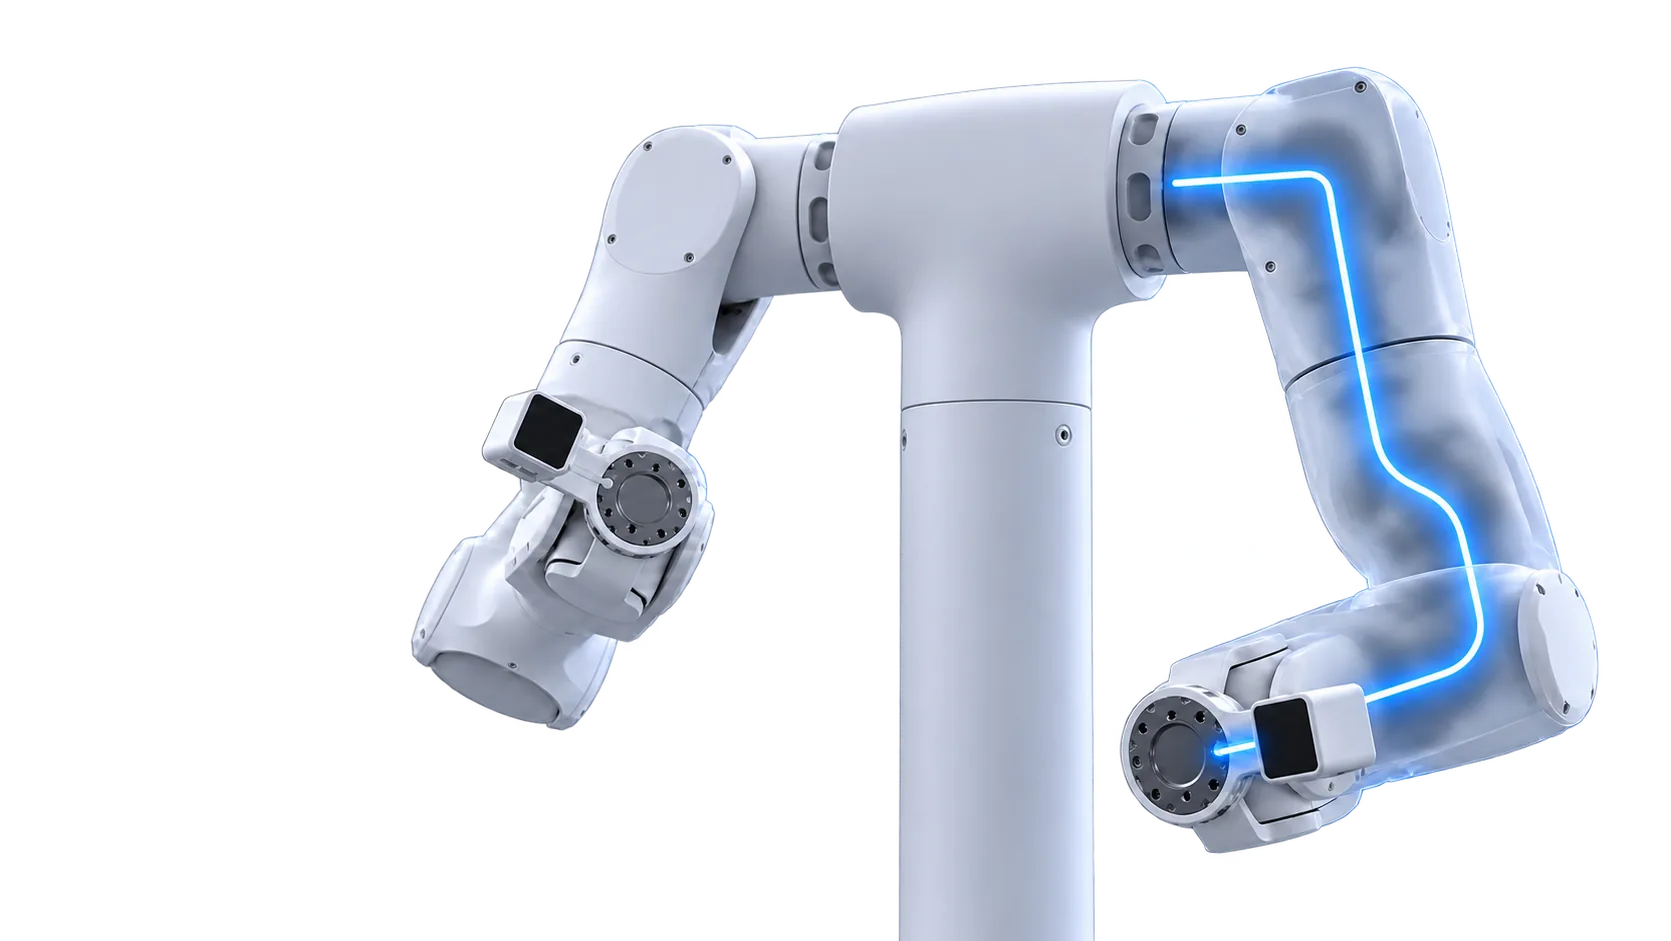
Large Hollow-bore Design with Internal Cable Routing
Easy Integration. Clean, Unobstructed Motion.
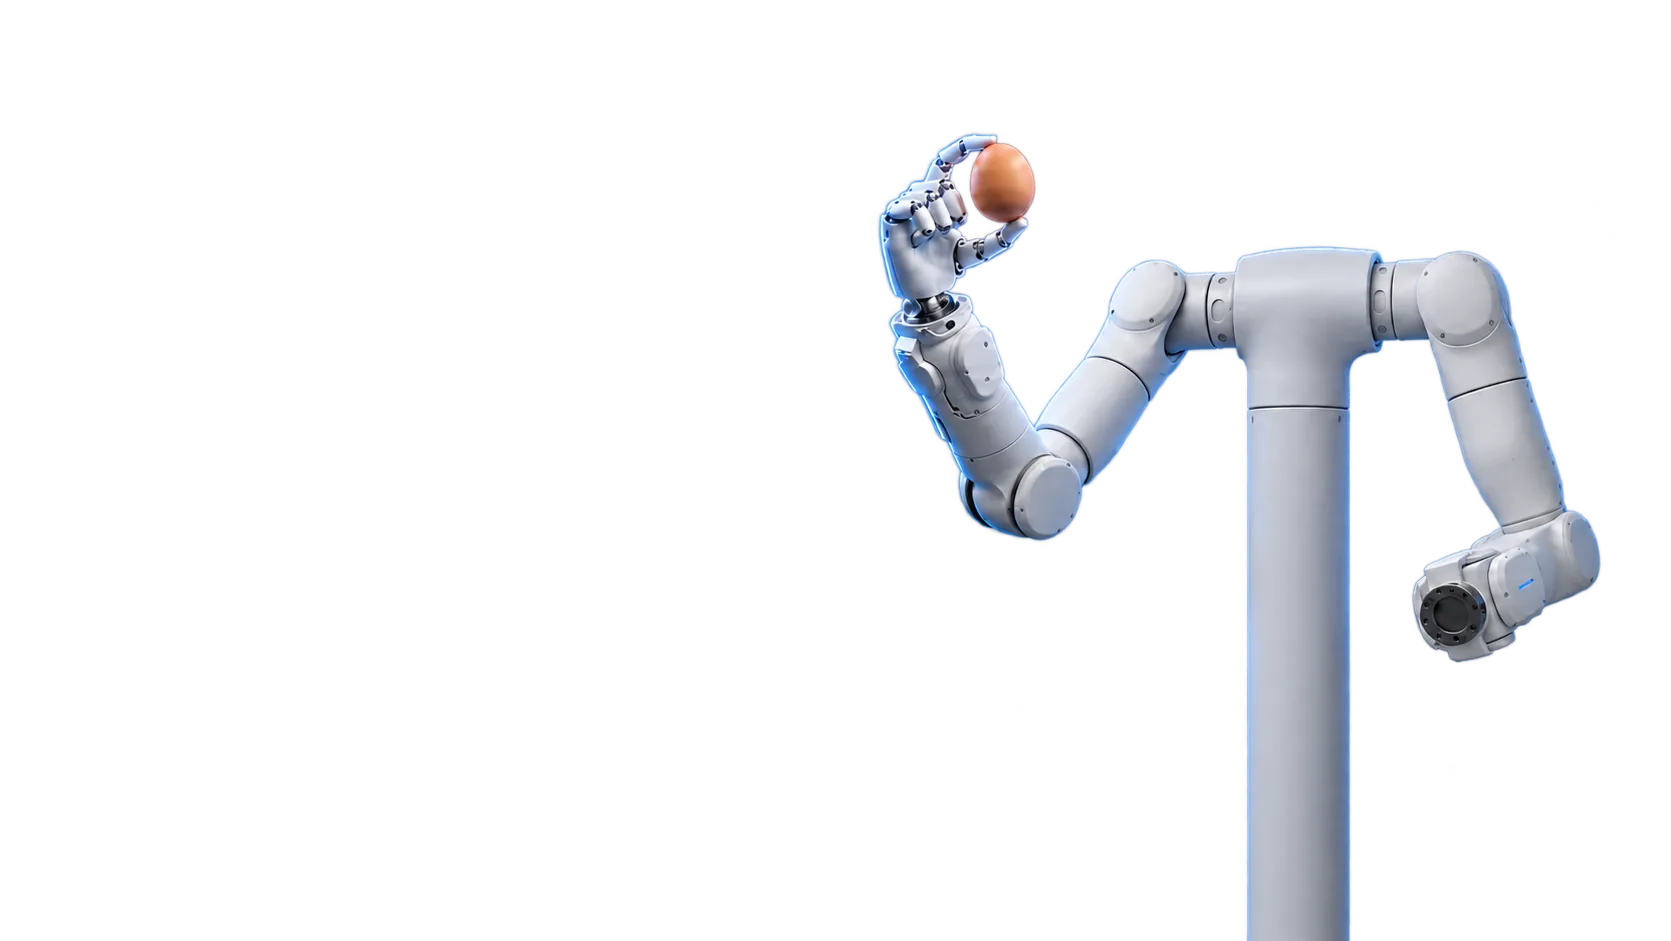
Torque Sensors as Standard on Every Joint
Collision Detection and Hand-guided Teaching
Bin Handling · Workstation Loading and Unloading · Equipment Operation · Door and Button Operation
EV Charging Connector Insertion and Removal · Connector Assembly · Wiring Harness Connection · Shaft-in-hole Assembly
Panel Handling · Long-part Assembly · Flexible Cable Management
Teleoperation · Imitation Learning · VLA Training · Torque Data Collection
Loading and Unloading · Inspection · Adhesive Dispensing · Screwdriving · Small-part Assembly
Force Control Research · Motion Planning · Dual-arm Coordination · Algorithm Validation
| Rated Payload | 7 kg |
|---|---|
| Reach | 725mm |
| Position Repeatability | ±0.03 mm |
| IP Rating | IP54 |
| Joint Brakes | Brakes on All Joints |
|---|---|
| Joint Torque Sensors | Standard |
| Force/Torque Control Accuracy | ≤ 0.15 N; ≤ 0.05 N·m |
| Force/Torque Control Resolution | ≤ 0.01 N·m |
| Closed-loop Force Control Bandwidth | ≥ 100 Hz |
| Degrees of Freedom | 7 |
|---|---|
| Arm Weight | 12 kg |
| Communication Protocol | EtherCAT |
| Tool Communication Interfaces | Two interfaces supporting EtherCAT, CAN, and RS-485 |
| Tool Power Interface | 24 V power supply (rated current: 3 A; maximum current: 5 A) |
| Input Voltage | 30–67 V DC; typical: 48 V DC (±15%) |
| Camera Cabling | GMSL cable internally routed to the tool end |
| Joint Range of Motion | J1: ±178° J2: -90° / +120° J3: ±178° J4: -60° / +145° J5: ±178° J6: ±60° J7: ±90° |
| Joint Speed | J1, J2: 180°/s J3–J7: 225°/s |
Take part in automation transformation. Let’s work together towards a more efficient tomorrow.